!ORIENTATION
Definition of local coordinate system
Parameter
2nd Line of later
- In case of
DEFINITION=COORDINATES
- In case of
DEFINITION=NODES
- In case of
DEFINITION=LOCAL_NODES
| Parameter Name | Attributions | Contents |
|---|---|---|
| a1, a2, a3 | R | coordinate of point a |
| b1, b2, b3 | R | coordinate of point b |
| c1, c2, c3 | R | coordinate of point c |
| a,b,c | I | Node ID of a,b,c, respectively (DEFINITION=NODES) |
| a,b,c | I | Local node number in the element of a,b,c, respectively (DEFINITION=LOCAL_NODES) |
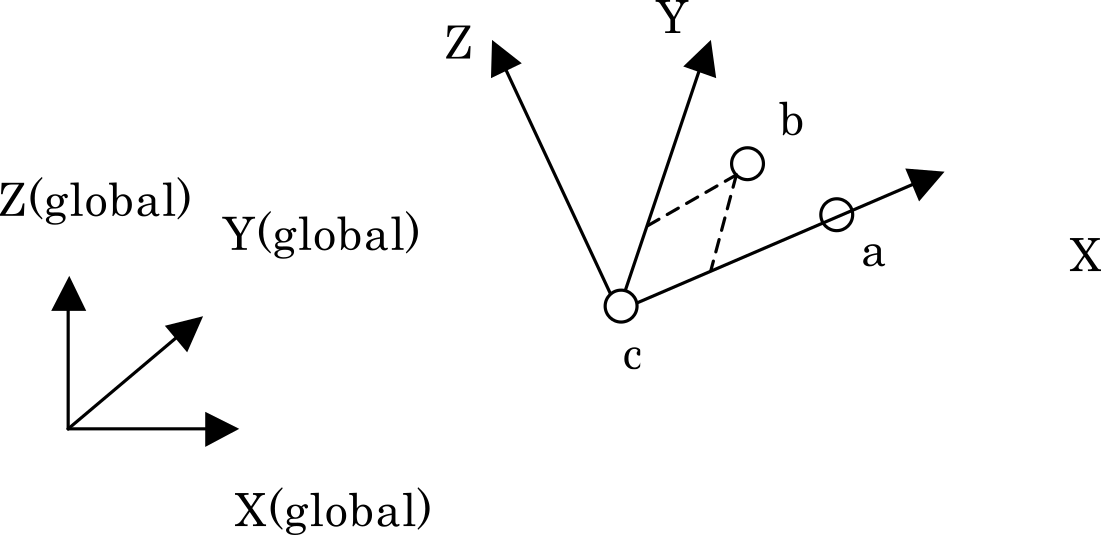
With DEFINITION=LOCAL_NODES, the local coordinate system of each element is defined from the coordinates of its own nodes a, b and c. The relation between a, b, c and the coordinate axes is as shown in the figure. Since the direction of the local coordinate system differs from element to element, it is used to give the material axes of an anisotropic material along the element shape. The local coordinate system is evaluated from the deformed nodal coordinates, and therefore follows the rotation and deformation of the element.
- All of a, b and c must be given. If any of them is omitted, an error occurs and the analysis stops.
- The local node numbers must be values from 1 to 10, and must not exceed the number of nodes of the element.
Example of Use
When the local coordinate system is defined from the local nodes 5, 1 and 8 of each element and applied to the section of SECNUM=1